Autonomous Harvesting Robot for Greenhouses
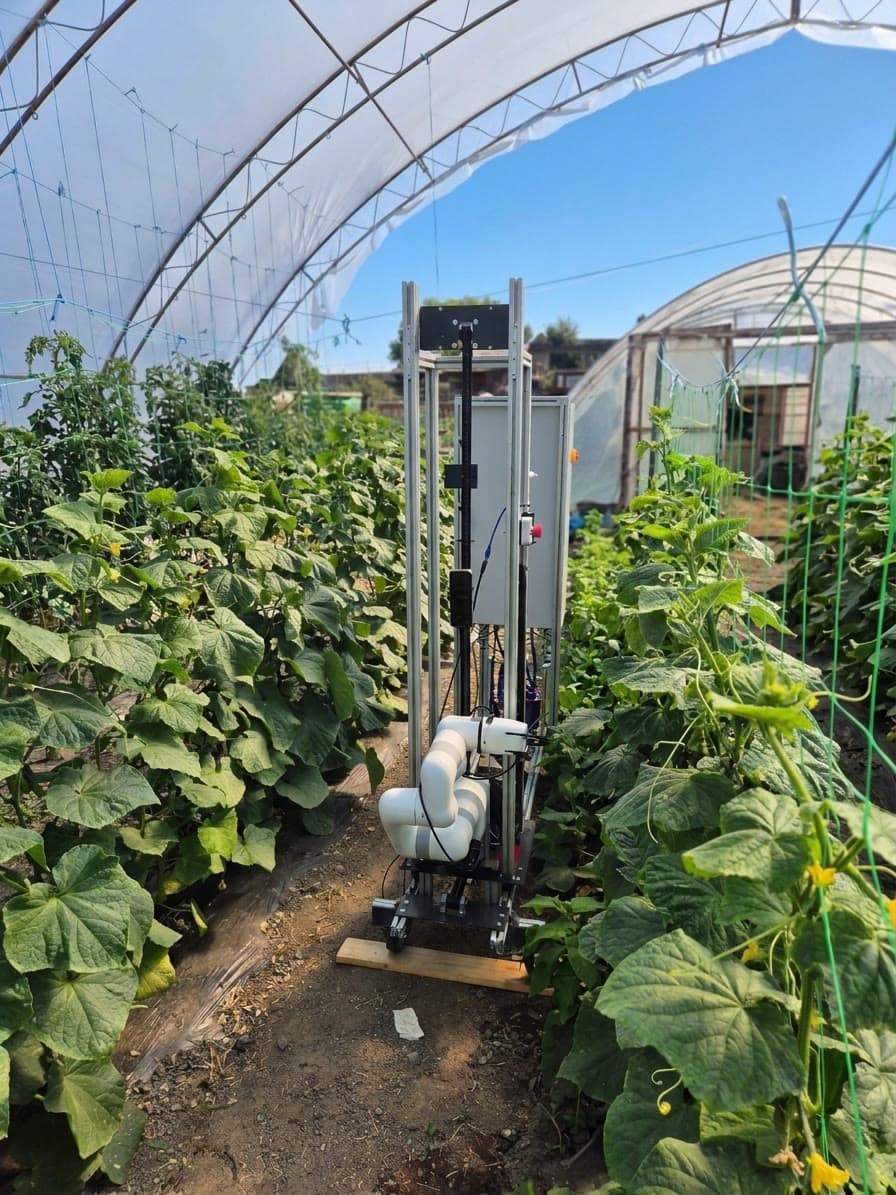
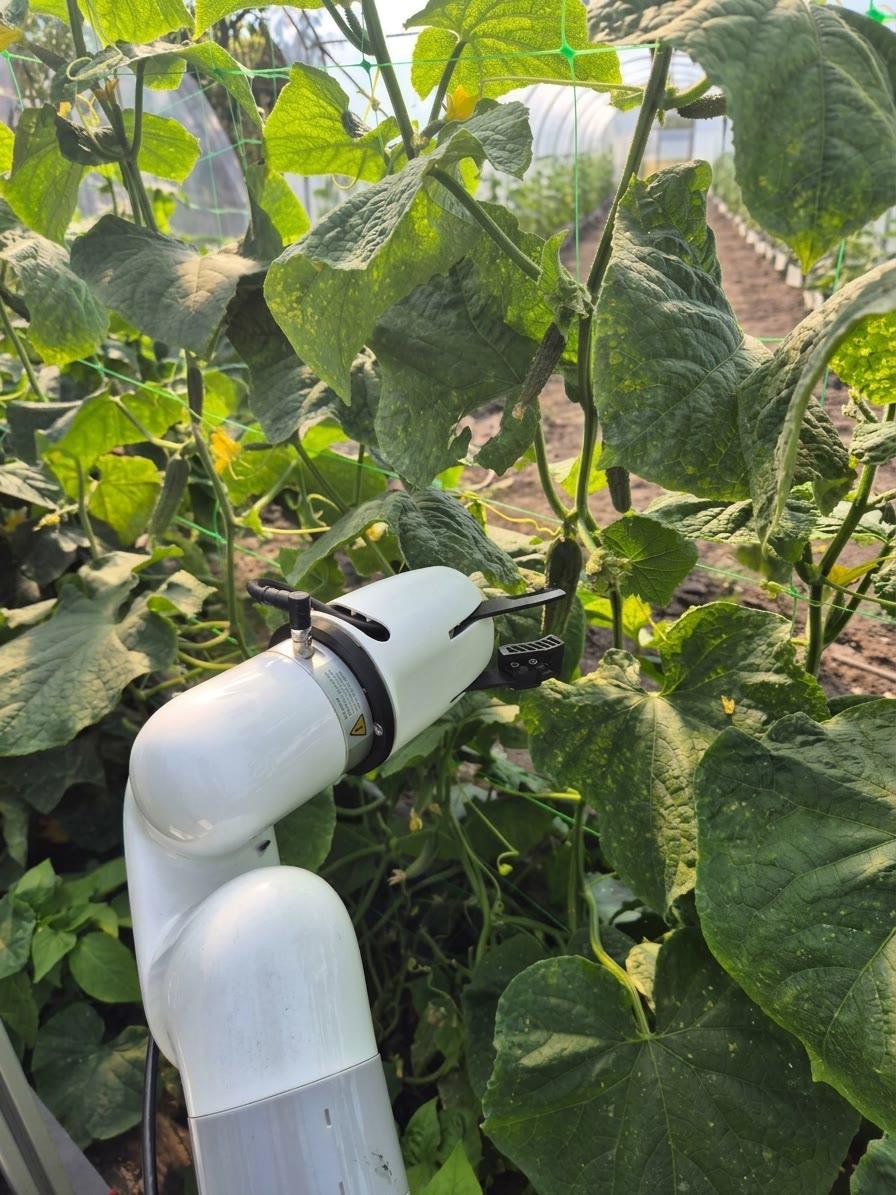
The system combines a mobile robotic platform, a robotic arm, computer vision and artificial intelligence to detect ripe fruit, determine its exact position and pick it with precision, without human control.
Built for greenhouse conditions
The robot is designed to move through the narrow rows of a greenhouse. Cameras and sensors handle navigation, obstacle detection and safe operation close to people working in the same space.
A dedicated gripping mechanism grabs, cuts and places each fruit into the container, with minimal damage to the plant.
Humans and robots working together
The robot handles routine picking on its own. When it runs into a situation it cannot resolve, it flags it and passes it to a worker through a digital interface. This keeps the harvest moving, reduces the need for manual labor and lets the available workforce focus where it is actually needed.
Technology
The system is built on ROS 2, which allows integration of advanced AI algorithms and coordination of multiple robots working in the same greenhouse.
Our goal
A reliable, flexible and commercially viable robotic solution that increases productivity and allows growers to automate their production step by step.
Main office
Šekspirova 40, 21000 Novi Sad, Serbia